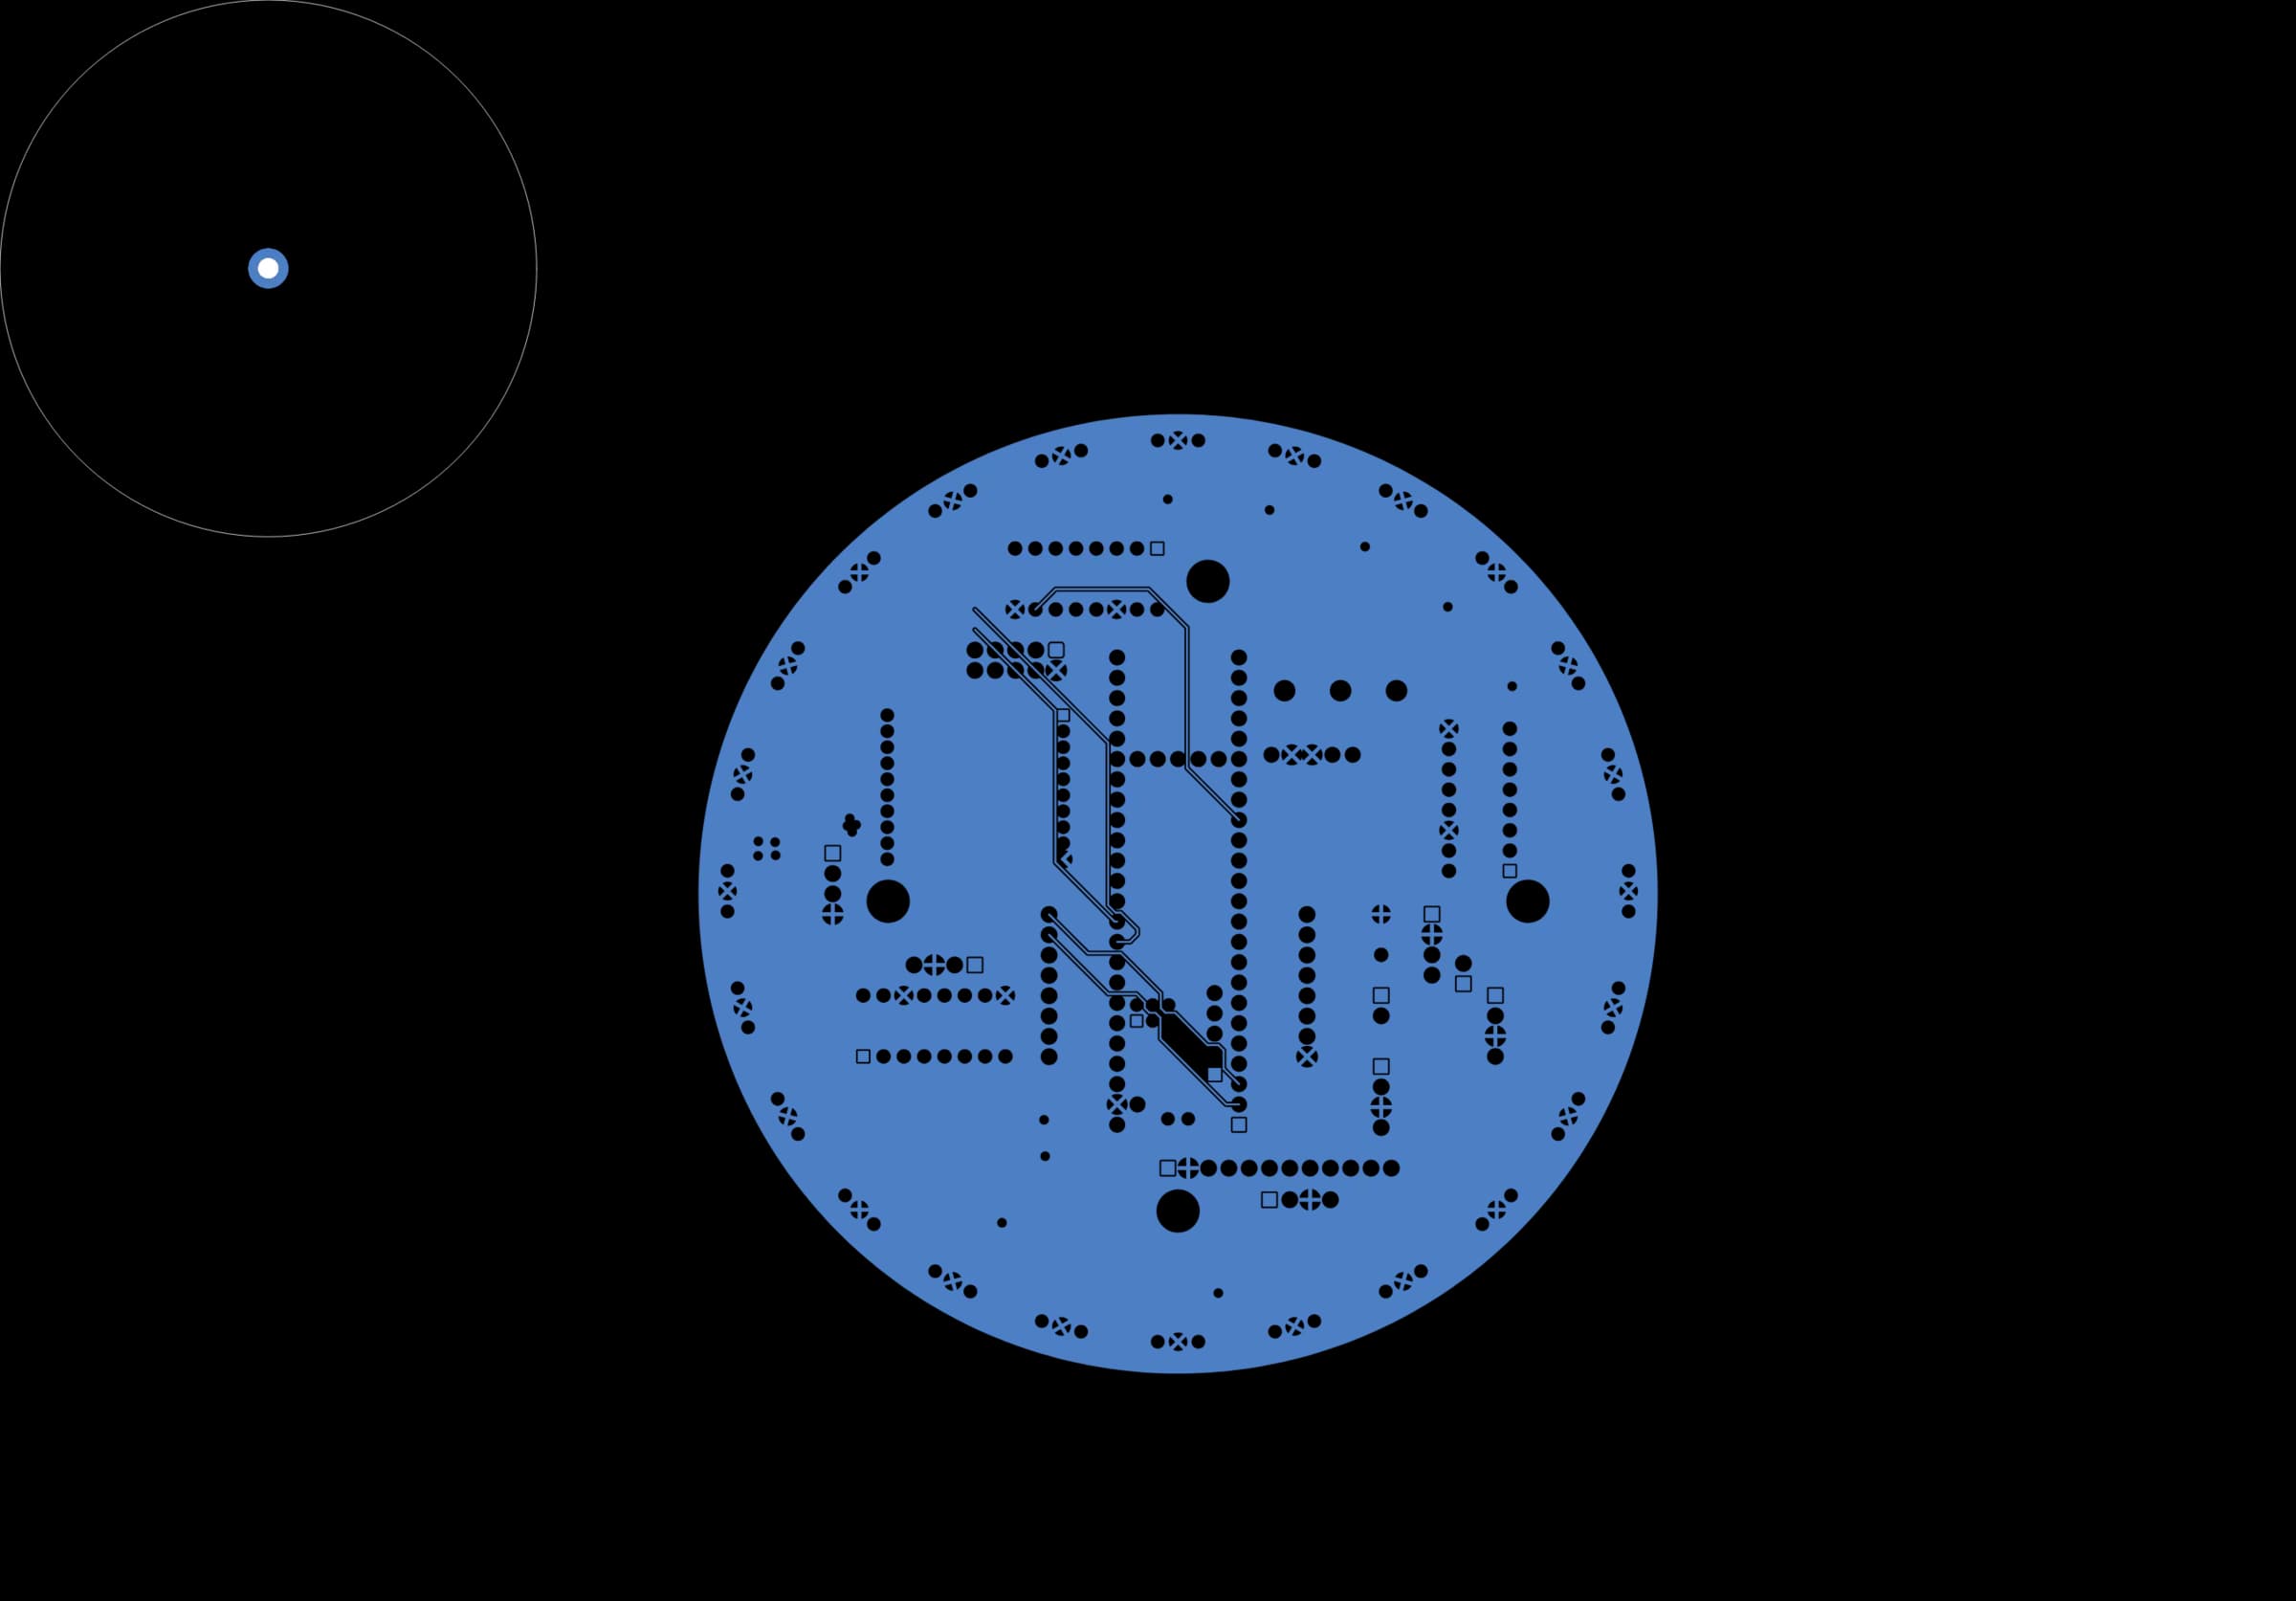
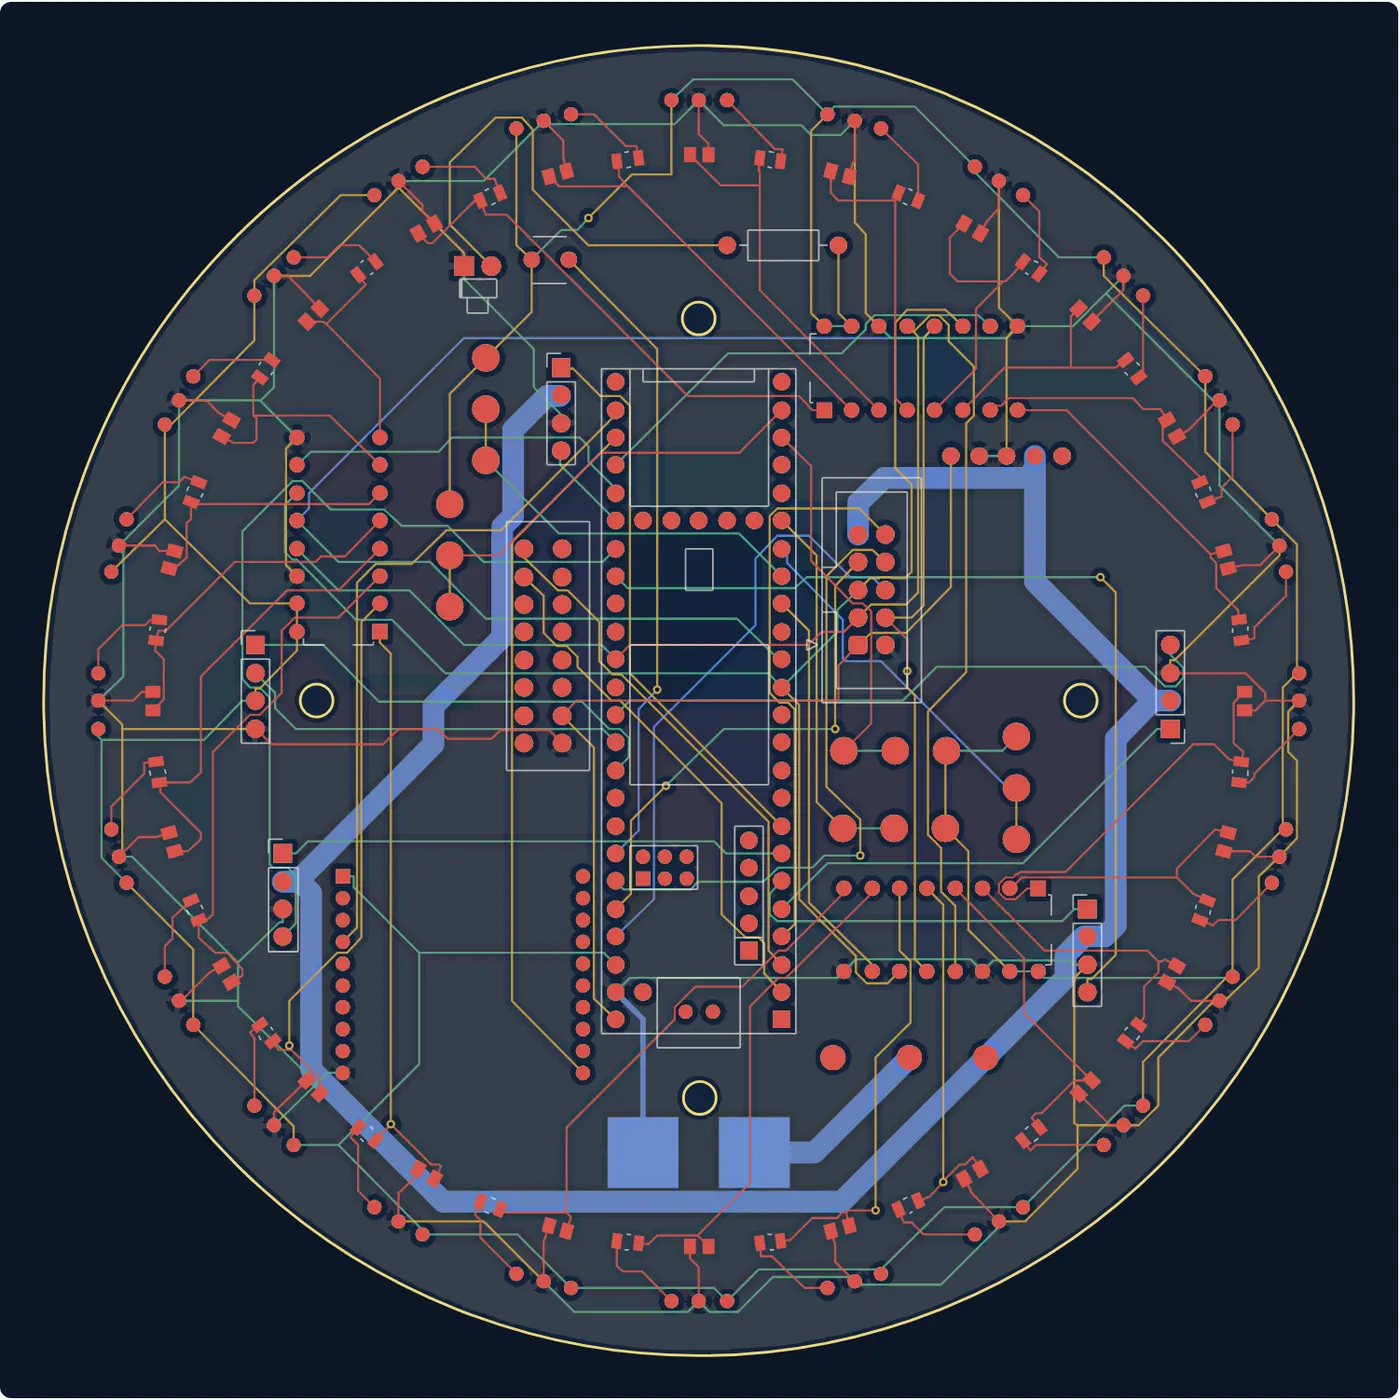
Robot main board
A four-layer, 120 mm round controller board, drawn in KiCad.
- Drawing
- DWG 02
- Revision
- Final
- Year
- 2024
- Role
- Schematic and layout
- Status
- Designed
- Type
- PCB, Electrical, Embedded
- Tools
- KiCad, Teensy 4.1, OpenMV H7, XBee
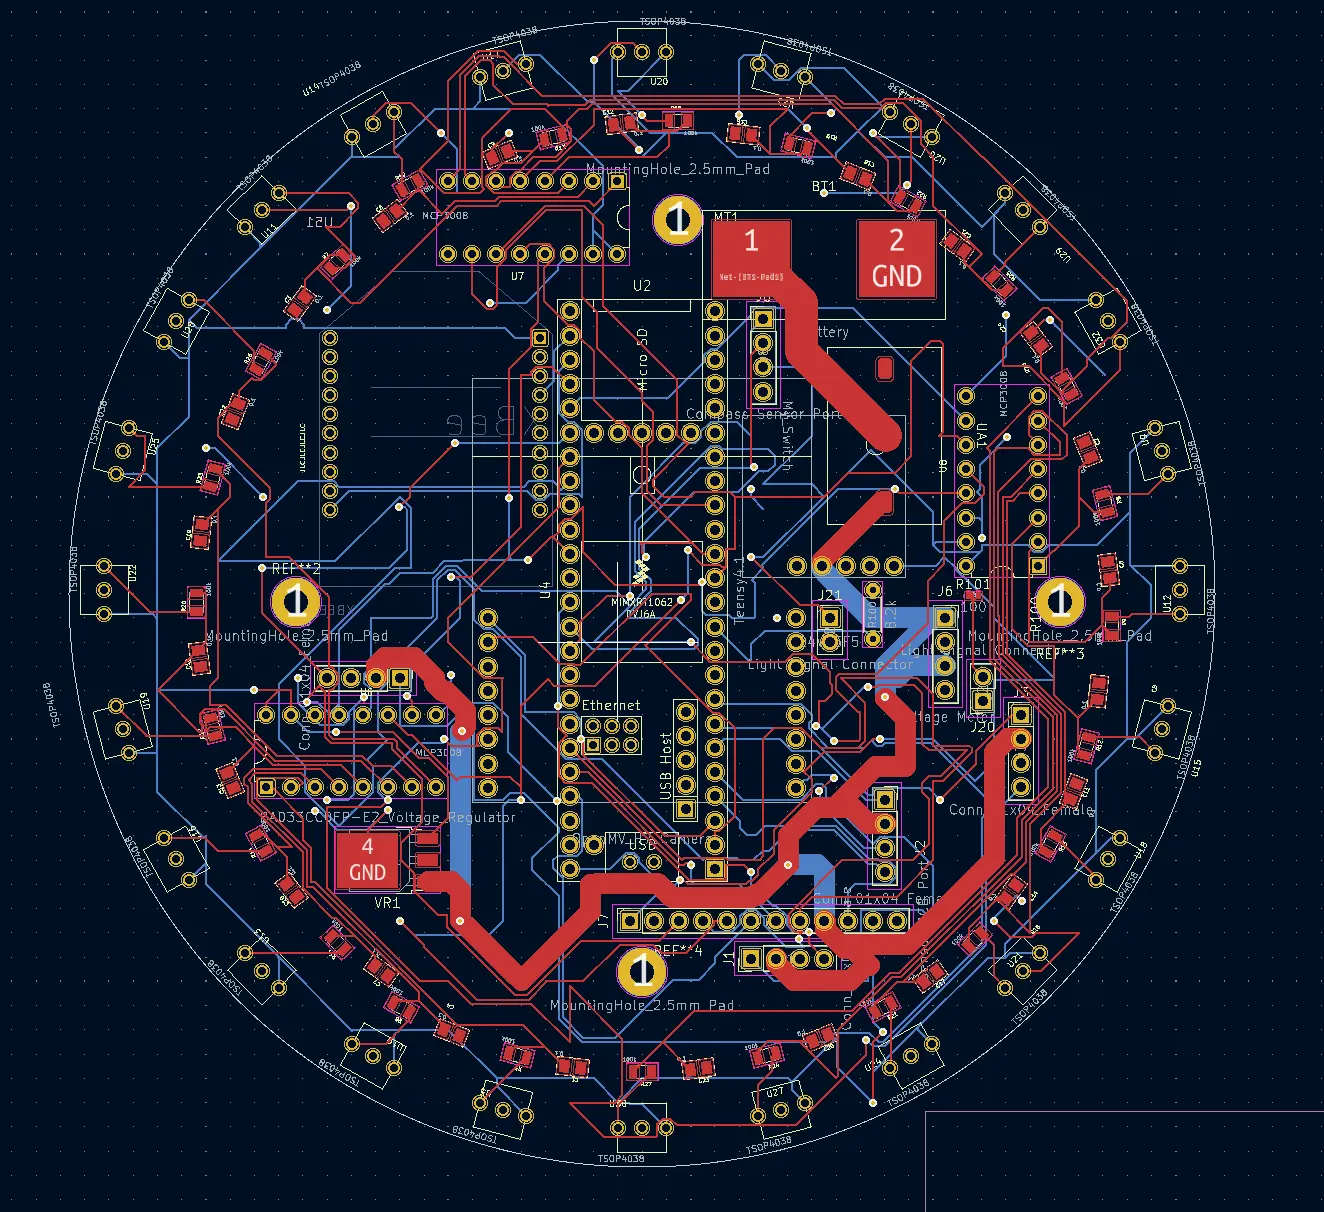
The controller board for a small autonomous soccer robot: a Teensy 4.1, a camera, a radio and a ring of 24 infrared receivers on one round, four-layer board. Toggle the copper layers below; the drawing is the real KiCad geometry.
Layers
Drawn in the browser from RoboCup.kicad_pcb. Top and bottom copper are on; switch on the two inner layers to see the routing between them.
Loading the board file…
On the board
- Controller
- Teensy 4.1
- Camera
- OpenMV H7
- Radio
- XBee S2C, robot to robot
- Ball sensing
- 24 TSOP4038 infrared receivers in a ring
- Analog inputs
- Three MCP3008 eight-channel ADCs
- Power
- Pololu D24V25F5 5 V regulator, battery connector
- Stack-up
- Four copper layers, 120 mm round outline, four mounting holes
- Files
- KiCad 6. The project folder keeps 33 timestamped backups, 6 to 27 January 2024.
Context
Built for RoboCupJunior Soccer, where two robots per team play on a small field with an infrared ball. The same robot used a separate line-sensor board and a kicker board; both are in the lab.